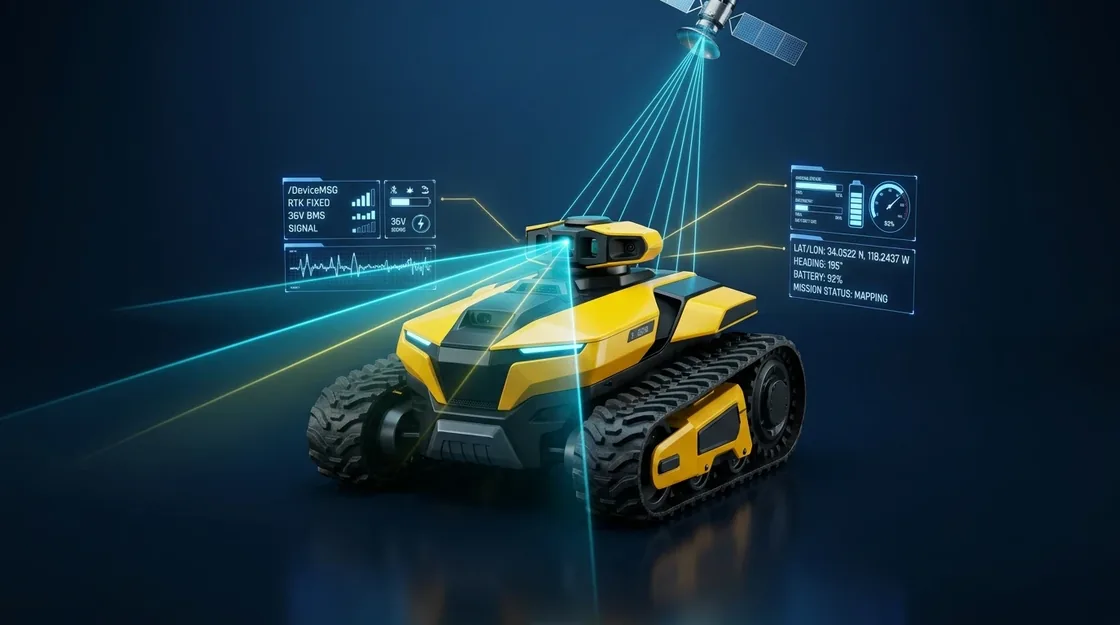
01 · TELEMETRY & CLOUD API
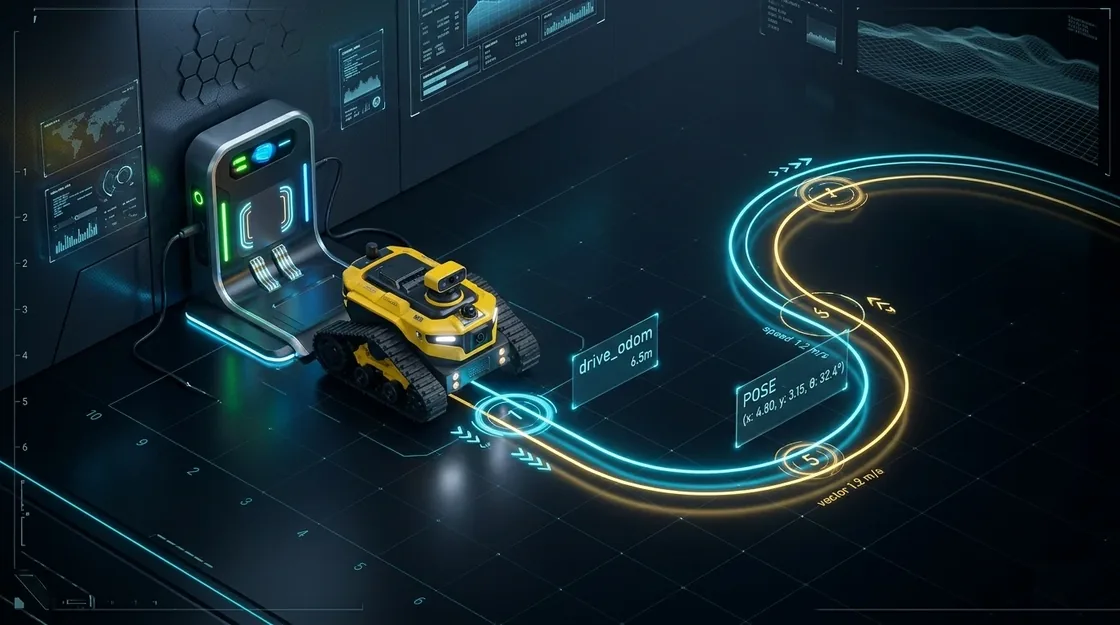
Live Telemetry, Map Editing & Schedule SDK
Stream centimeter RTK pose and 36V BMS states over TLS 8883 with map & plan CRUD.
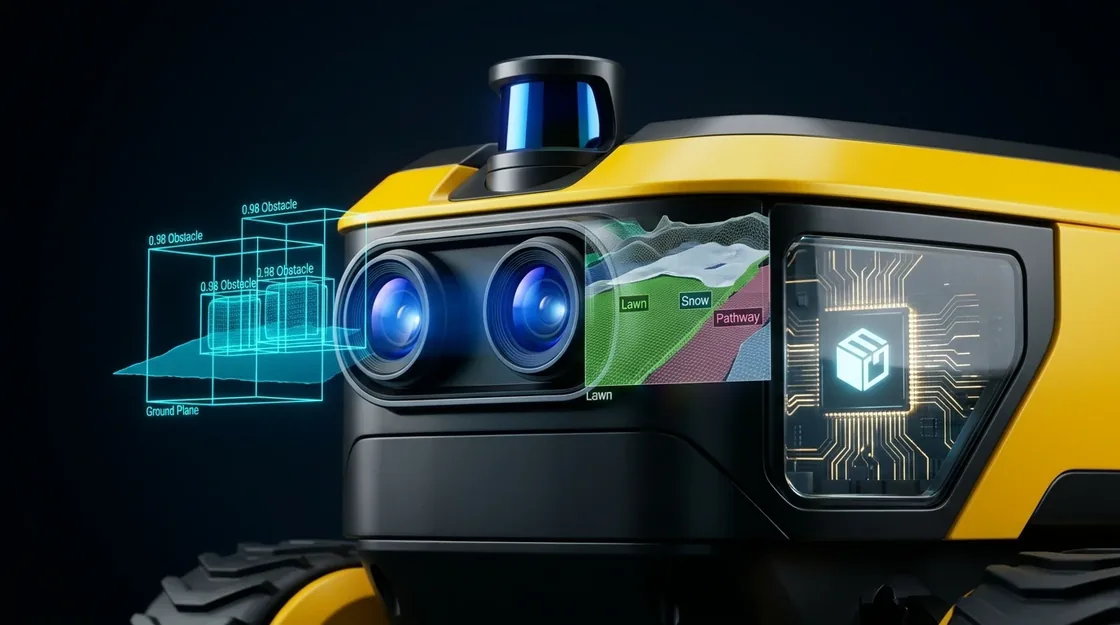
Open Python SDK, On-Robot Linux Edge Containers, and a standardized Hardware Attachment Bus—turning Yarbo into a programmable mobile base.
from yarbo_sdk import YarboAccount

with YarboAccount(environment="prod") as account:
    account.login(email, password)
    robot = account.robot("26350102U9BFX597")

    # Live telemetry & GPS-denied closed-loop garage undocking
    snap = robot.status()
    robot.undock()
    odom = robot.drive_odom(6.5, speed_m_s=0.25)
Full-Stack Open Platform
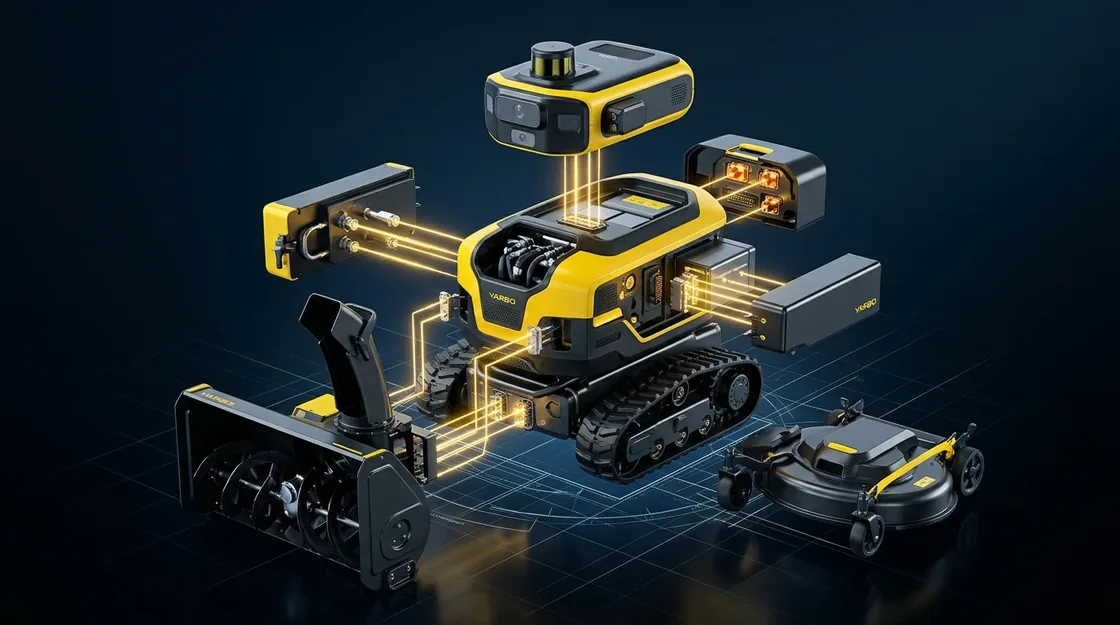
Modular Hardware & L0–L4 Architecture
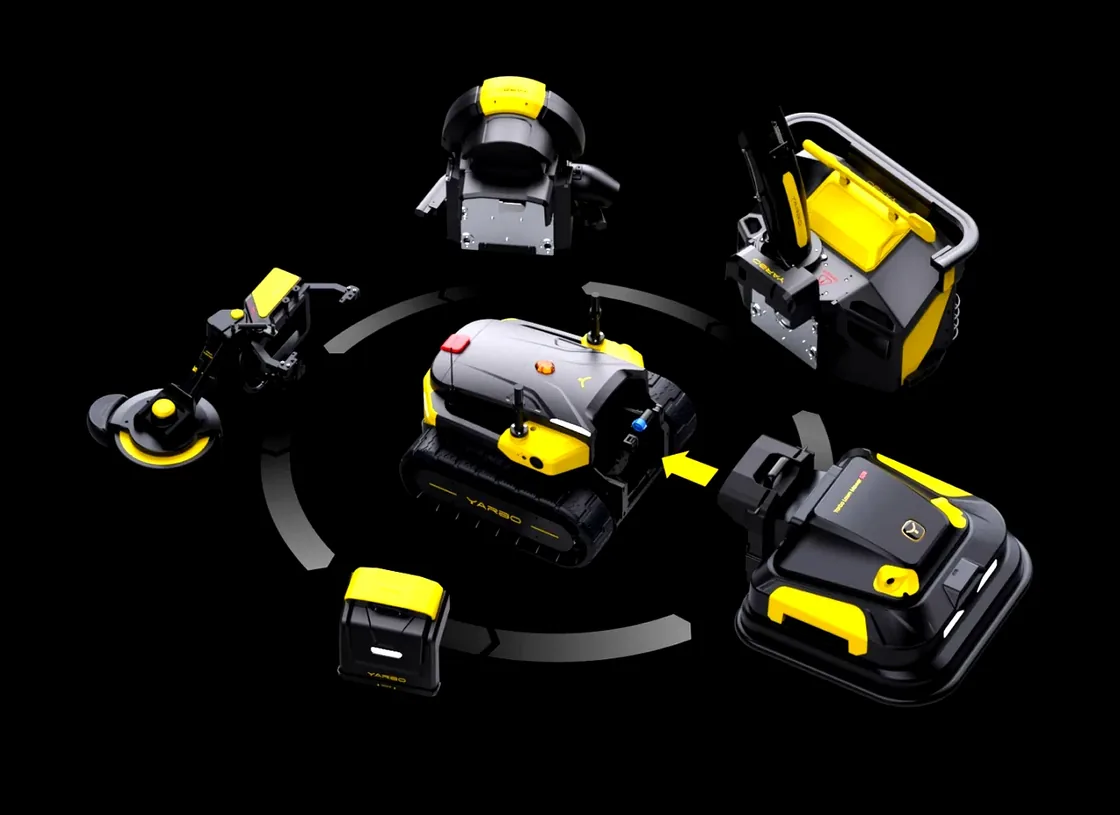
Auger RPM (850–1800) + linear actuator (0–64), pre-checked against head_type & E-Stop.
robot.run_module("snow_roller", command_value=1650, duration=3.0)
session.send_command(device_id, action="head_down", confirm=True)HDK v1.0 · Open Hardware Development Kit (Universities & Hardware Makers)

Click pinout schematic to inspect high-resolution vector details (Ref: 26YM-C1-Controller V1.0.4)
| COB-ID / Index | Dir / Cycle | Signal / Register | Scale & Safety Interlock |
|---|---|---|---|
SDO 0x0000:01 |
RO · Handshake | HEAD_TYPE (0x600+ID / 0x580+ID) |
1=Snow, 2=Blower, 3=Mower, 0x10..0x1F=Custom 3P |
SDO 0x0001:00 |
RW · Event | BLDC_PWM_CMD / PUSH_ROD (:02) |
Primary motor command (int16) · Push-rod target 0–64 mm |
TPDO1 0x180+ID |
TX · 100ms | rpm(B0..1) · curr_mA(B2..3) · rod_mm(B4..5) |
Live RPM, current (mA), push-rod position & fault mask (B6..7) |
TPDO2 0x280+ID |
TX · 200ms | vbat_mV(B0..1) · 24V(B2) · 12V(B3) · temp(B4..5) |
Battery bus voltage (26–42V), 24V/12V rails (0.1V) & temperature |
TPDO 0x68C |
BC · 100ms | Bit 32: emergency_stop · Bit 33..34: hook_lock |
Chassis E-Stop broadcast; halt PWM within 50 ms on Bit32=1 or >500 ms loss |
Developer Console
Receive client_id / client_secret immediately (shown once, 10 req/min).
Upgrade to 60 req/min after sandbox validation.